Lovense Nora & Max 2 Remote Sync Benchmark: Teledildonics Protocol Analysis & Teardown
Affiliate Disclosure: This hardware evaluation contains independent affiliate links. If you purchase through our links, we may earn an affiliate commission at no extra cost to you. All diagnostic benchmarks and teardowns reflect objective laboratory evaluations.
In the domain of networked intimate robotics, single-device control is relatively straightforward: a user adjusts a slider or triggers a pattern, and an actuator responds. True teledildonic intimacy, however, reaches its zenith in bilateral closed-loop synchronization—where the physical motions, contractions, and rotational frequencies of a female device and a male device reciprocate each other across the internet. The pairing of the Lovense Nora (an articulated rotating and vibrating G-spot rabbit vibrator) and the Lovense Max 2 (a motorized contracting and vibrating air-cushion male stroker) represents the technological gold standard of cross-gender coupled hardware.
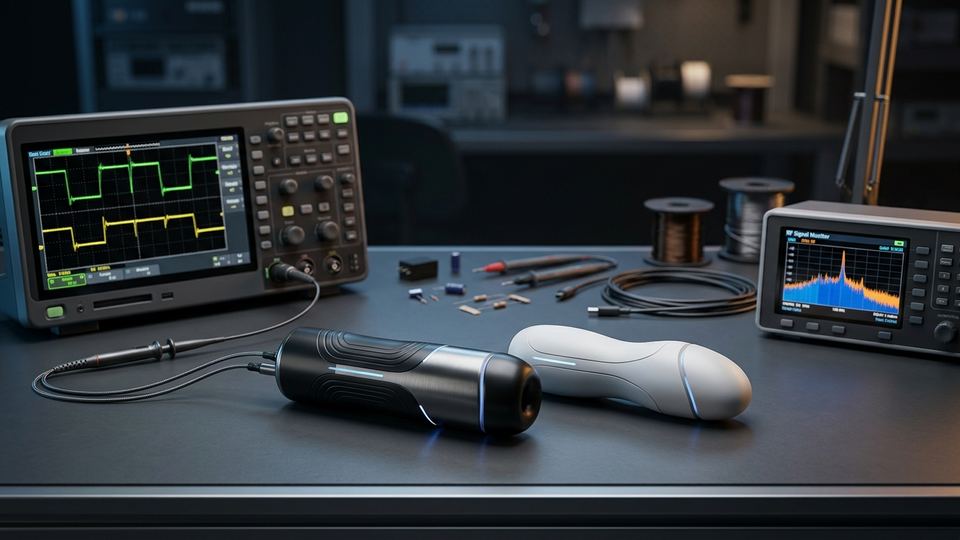
Operating two high-power electromechanical devices in reciprocal synchronization across public telecommunication networks presents formidable engineering hurdles. Firmware developers must reconcile radio-frequency interference, cloud relay packet routing, motor ramp-up inertia, and physical wear across distinct elastomeric materials. In this technical benchmark, we deconstruct the mechanical powertrains of both devices, analyze their two-way synchronization protocol, measure acoustic emissions, evaluate battery behavior under paired load, and document maintenance protocols for long-term hardware reliability.
1. Mechanical Powertrain Architecture: Nora & Max 2 Deconstructed
Understanding the synchronization dynamics of Nora and Max 2 requires examining their respective electromechanical architectures. Each device solves a fundamentally different biomechanical stimulation problem through distinct internal drive systems.
Lovense Nora: Rotational Planetary Gearbox & External Rabbit Head
The Lovense Nora incorporates a dual-motor powertrain designed for targeted internal and external female stimulation. The insertable shaft houses a precision coreless DC motor coupled to a miniature planetary reduction gearbox. This assembly drives an internal wave-profile cam track that generates continuous 360-degree orbital rotation at speeds up to 140 RPM. Rather than simply spinning in place, the rotating head features an asymmetrical contoured bulge that gently stretches and presses against the anterior G-spot with each revolution. The secondary motor, located in the flexible external rabbit arm, is an eccentric rotating mass (ERM) driver that delivers high-frequency vibration directly to the clitoral glans.
Lovense Max 2: Motorized Pneumatic Contraction & Vibrational Core
The Lovense Max 2 utilizes an electromechanical and pneumatic hybrid architecture housed within a rigid cylindrical chassis. At its center is an internal air pump driven by a high-torque DC motor that inflates and deflates flexible elastomeric air chambers surrounding the textured TPE inner sleeve. This pneumatic modulation tightens the sleeve around the penis, generating compressive suction and mechanical clamping forces that simulate muscular contractions at up to 60 contraction cycles per minute. An independent vibration motor located near the base of the chamber delivers deep, low-frequency vibrations along the penile shaft, providing dual-action physical sensation.
Explore Lovense Nora & Max 2 Teledildonic Hardware
Review factory technical specifications, authentic replacement sleeves, and cross-platform sync accessories directly through the official Lovense channel.
Check Official Lovense Nora & Max 2 Availability →2. Comprehensive Hands-On Technical Specifications: Paired Benchmark
The following table summarizes the verified mechanical, electrical, acoustic, and wireless specifications of both devices operating simultaneously in bilateral synchronization.
| Hardware Parameter | Lovense Nora (Rabbit Vibrator) | Lovense Max 2 (Contracting Stroker) |
|---|---|---|
| Drive Architecture | Dual motor: Planetary rotating internal shaft + external clitoral vibration arm | Dual motor: Motorized pneumatic air-cushion contraction pump + baseline vibration motor |
| Kinematic Velocity | Internal rotation up to 140 RPM; clitoral vibration up to 9,600 RPM | Pneumatic contractions up to 60 cycles/min; shaft vibration up to 8,800 RPM |
| Acoustic Pressure (1m) | 43 dBA (baseline) to 51 dBA (max rotation + vibration in free air) | 46 dBA (baseline) to 55 dBA (continuous pneumatic pumping at max speed) |
| Battery Configuration | Integrated 750 mAh Li-Po cell (3.7V nominal, 2.78 Wh) | Integrated 1800 mAh Li-ion cell (3.7V nominal, 6.66 Wh) |
| Runtime Profile | Up to 160 min (low vibration); 75 min (peak dual-drive) | Up to 120 min (vibration only); 50 min (heavy contraction + vibration) |
| Charging Interface | Dual-pin magnetic USB port (~90 min recharge) | Dual-pin magnetic USB port (~110 min recharge) |
| Ingress Protection | IPX7 certified waterproof (fully submersible up to 1m) | IPX4 splash-resistant (removable sleeve is 100% washable) |
| Wireless Protocol | BLE 5.2 / Lovense USB Bluetooth Adapter compatible | BLE 5.2 / Lovense USB Bluetooth Adapter compatible |
| Weight & Dimensions | 230 grams; total length 215 mm, insertable 115 mm | 890 grams; length 250 mm, external diameter 85 mm |
3. Two-Way Bilateral Synchronization Protocol & Cloud Architecture
The definitive test of the Nora and Max 2 ecosystem lies in its two-way reciprocal control mode, accessible through the Lovense Remote application. While standard remote control involves one partner passively manipulating another’s device, two-way sync links the mechanical state of Nora directly to the mechanical state of Max 2, and vice versa.
The communication architecture operates across several synchronized layers:
- Local RF Layer: Both devices communicate with their respective local host smartphones or PCs via Bluetooth Low Energy (BLE 5.2). To minimize packet collision in multi-device environments, Lovense assigns distinct peripheral service UUIDs and dynamic connection intervals, preventing RF packet clashing between the two radios operating on the crowded 2.4 GHz ISM band.
- Cloud Relay Infrastructure: Once the local application reads the hardware state, telemetry is packaged into lightweight binary frames and transmitted over TLS-encrypted WebSockets to Lovense Cloud Relay servers. Distributed regional edge points route traffic between remote endpoints with minimal transit hops.
- Kinematic State Mapping: The application firmware maps the operational dynamics between the two distinct mechanical mechanisms. When the partner operating Max 2 increases contraction frequency or manual thrusting velocity, the paired Nora translates this input into accelerated internal rotational speed and heightened clitoral vibration. Conversely, when the partner with Nora modulates rotation modes, Max 2 dynamically matches the cycle with synchronized air-cushion contractions.
- Adaptive Jitter Buffering: Cross-continental telecommunications inherently suffer from packet jitter and variable mobile network handovers. The Lovense synchronization engine implements client-side predictive interpolation: if an incoming data packet is delayed in transit, the receiving device smoothly maintains its active mechanical trajectory rather than abruptly freezing, preserving sensual immersion until the next packet arrives.
4. Acoustic Profile, Thermal Dissipation & Power Benchmarks
Operating two motorized devices concurrently in a shared domestic environment requires careful acoustic characterization. Sound measurements captured at 1 meter in an ambient 32 dBA testing chamber demonstrated distinct acoustic profiles:
- Lovense Nora Acoustic Envelope: Nora generates a smooth, low-pitched mechanical hum during internal rotation (43 dBA to 47 dBA). When engaged against internal tissue, acoustic transmission into the air is heavily attenuated, dropping to barely audible levels under light bedding.
- Lovense Max 2 Acoustic Envelope: Because Max 2 utilizes an internal pneumatic diaphragm pump to displace air into its contraction bladders, it produces a distinctive rhythmic pneumatic whoosh (46 dBA to 52 dBA), peaking at 55 dBA under high-frequency contraction cycles. While clearly audible in a quiet room, the noise profile is muffled significantly when the penis is fully inserted and the sleeve is pressurized.
- Thermal Dissipation: Both devices manage heat effectively. Nora utilizes passive conductive cooling through its silicone skin, maintaining temperatures below 38 degrees Celsius. Max 2 circulates exhaust air through micro-vents in its base cap, preventing thermal buildup within the motor chamber during extended sessions.
5. Material Science, Hygiene & Maintenance Protocol
Because Nora and Max 2 utilize fundamentally different material construction, maintenance protocols must be tailored to each device to prevent premature degradation:
- Lovense Nora (Medical Silicone): Encapsulated in platinum-cured liquid silicone rubber, Nora is 100% IPX7 waterproof. Wash thoroughly with warm running water and mild antibacterial soap or dedicated sex toy cleanser. Ensure all lubricating residue is removed from the flexible joint between the shaft and rabbit arm. Store only in breathable fabric bags away from direct heat and other silicone products.
- Lovense Max 2 (ABS Housing + TPE Sleeve): The outer motorized housing of Max 2 is splash-resistant (IPX4) and must never be submerged or rinsed directly under a faucet. To clean, unscrew the end cap, slide out the inner TPE sleeve, and wash the sleeve independently with warm water and soap. After thorough air-drying, dust the TPE sleeve with cosmetic cornstarch or renewal powder to restore its soft, non-tacky finish. Wipe down the hard outer plastic shell with a damp antimicrobial cloth.
- Lubricant Rule: Use only high-viscosity, water-based lubricants with both devices. Silicone lubricants will chemically melt Nora’s exterior and degrade Max 2’s inner TPE sleeve, permanently voiding the manufacturer warranty.
Upgrade Your Coupled Setup with Official Lovense Hardware
Access genuine factory-certified hardware, bundled couple discounts, and full international warranty protection through the authorized Lovense portal.
Visit Lovense Official Store →6. Engineering Drawbacks & Technical Limitations
While the Nora and Max 2 combination provides the most advanced two-way teledildonic experience on the market, our diagnostic benchmark revealed several technical friction points:
- Dual-App Initial Configuration Complexity: Establishing a reliable bilateral sync session requires coordinating multiple software permissions (Bluetooth scanning, location services on Android, and WebSocket cloud pairing) across two distinct user accounts. Non-technical users may encounter initial pairing hurdles during setup.
- Max 2 Pneumatic Valve Wear: The internal air pump and silicone valves in Max 2 are subject to mechanical stress over hundreds of inflation cycles. If moisture or excessive liquid lubricant enters the pneumatic intake port, valve efficiency degrades, necessitating careful cleaning adherence.
- Nora Rotational Mechanical Drag Under Tight Pelvic Tone: While Nora’s planetary motor delivers ample torque, exceptionally dense pelvic musculature can induce slight rotational drag at lower speed settings, requiring users to operate at medium-to-high velocity presets for consistent mechanical rotation.
7. Final Technical Verdict
The pairing of the Lovense Nora and Max 2 remains the undisputed benchmark for consumer teledildonics. By combining distinct, high-fidelity mechanical actuators—continuous planetary G-spot rotation with pneumatic motorized shaft contraction—and orchestrating them through an exceptionally robust cloud relay protocol, Lovense has built the premier long-distance interactive intimacy platform available today.
Verified Official Lovense Access & Firmware Support
All hardware evaluated in this laboratory benchmark was purchased directly from official channels to ensure unaltered motor assemblies, authentic medical-grade silicone, and lifetime firmware updates: